
Research
Preprints1 preprint
-
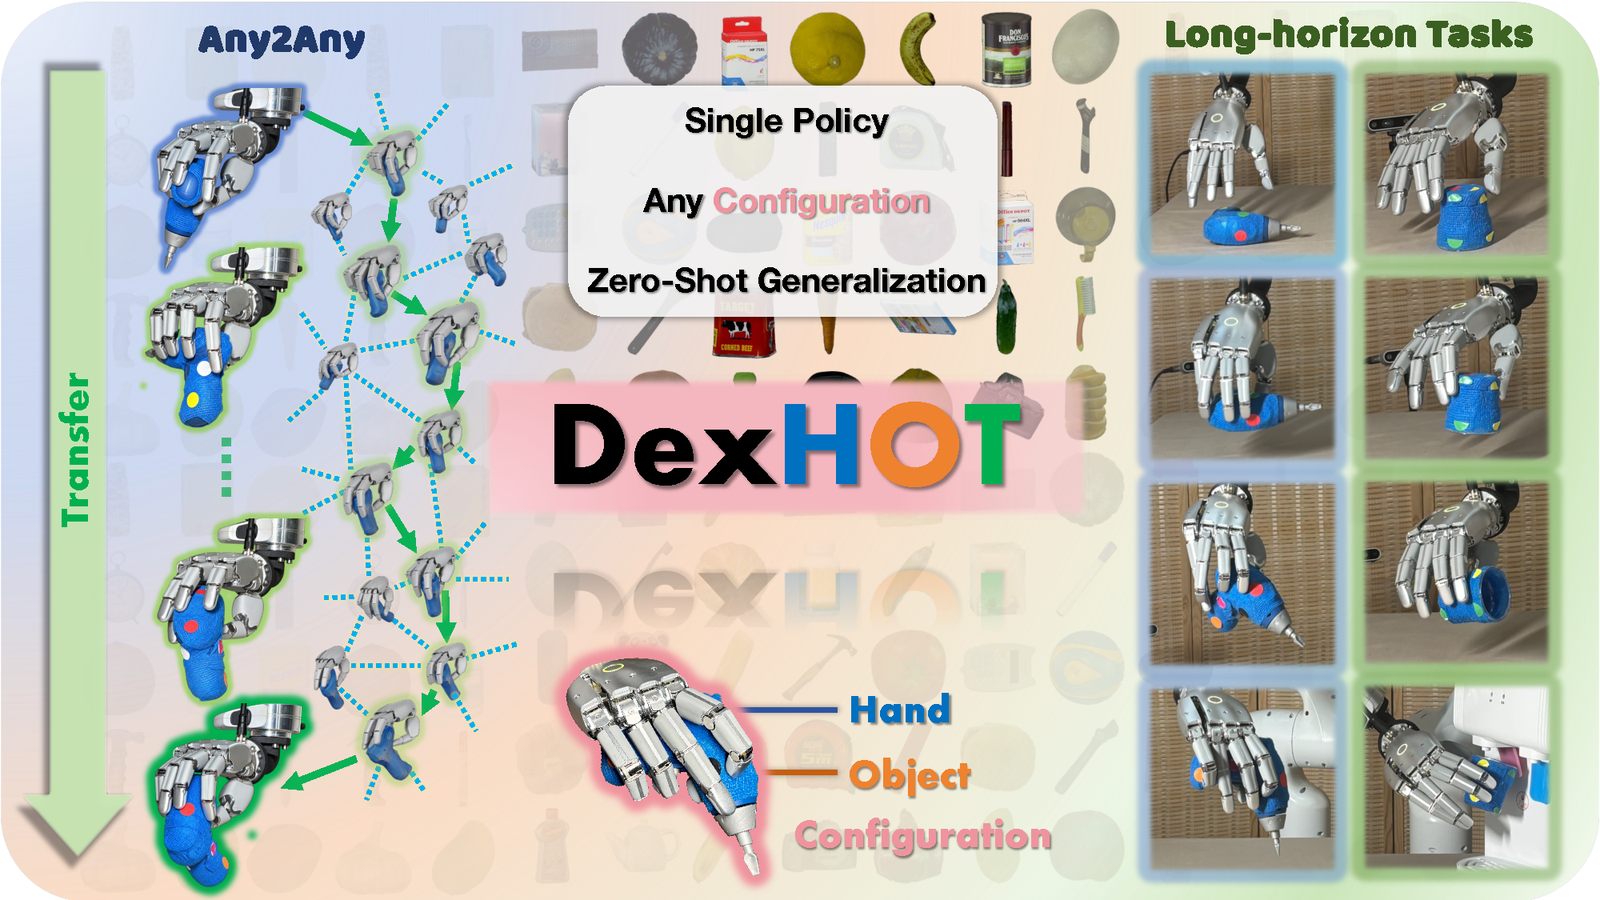
DexHOT: Learning Hand–Object Configuration Transfer for Dexterous Manipulation
In submission 2026
We address dexterous manipulation through hand–object configuration transfer, jointly specifying hand articulation and object pose relative to the wrist. A single relation-conditioned policy learns reusable transfers from synthetic configuration pairs and composes them into long-horizon behaviors, with evaluation on unseen objects and a real dexterous hand.
Publications2 publications
-
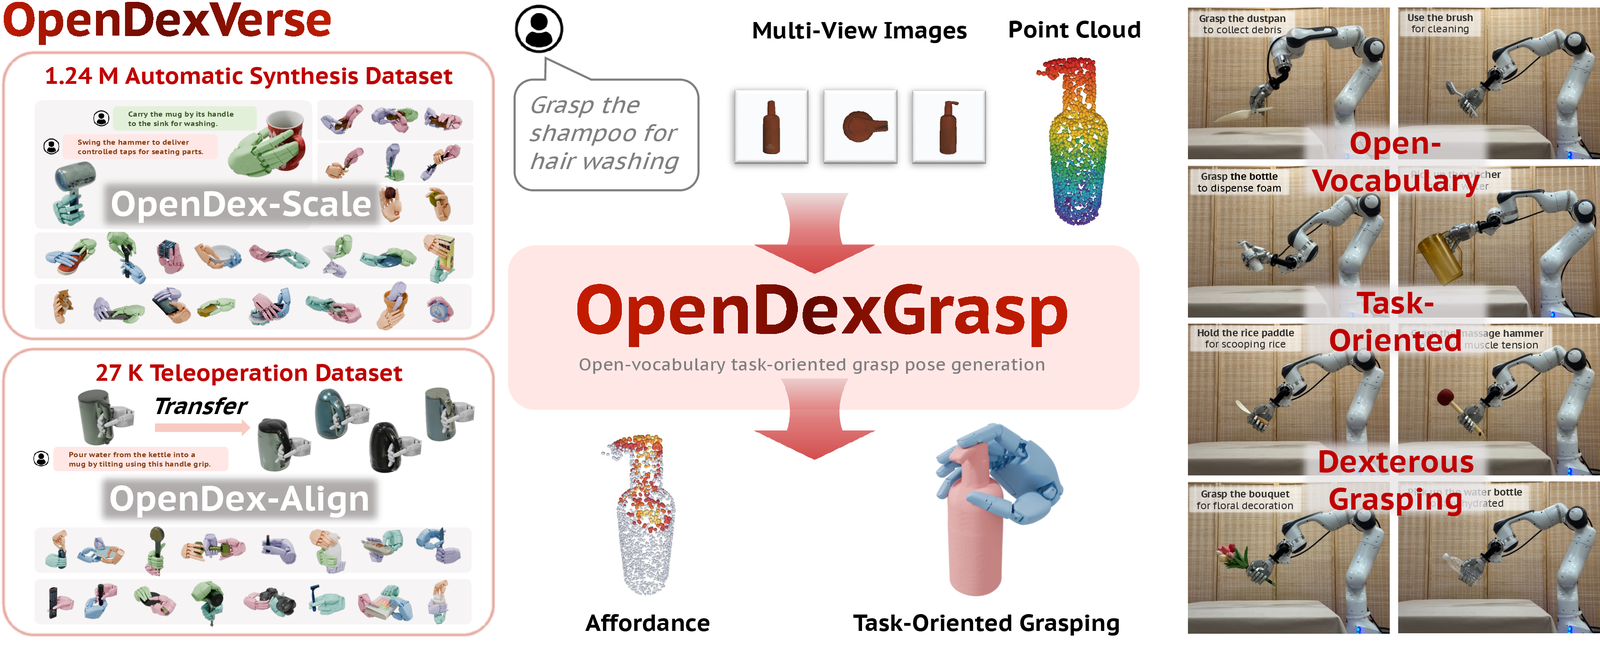
OpenDexGrasp: Open-Vocabulary Task-Oriented Dexterous Grasping
[CoRL 2026] Conference on Robot Learning 2026 Oral (1 of 21 oral presentations among 687 accepted papers, selected from 2,094 submissions; 3.1% of accepted papers · 1% of submissions)
We address open-vocabulary task-oriented dexterous grasping by integrating language instructions, multi-view observations, and object geometry in a shared perception–action representation. Joint affordance grounding and grasp generation are trained with synthetic data and human demonstrations to produce task-consistent grasps that generalize to unseen object categories.
-
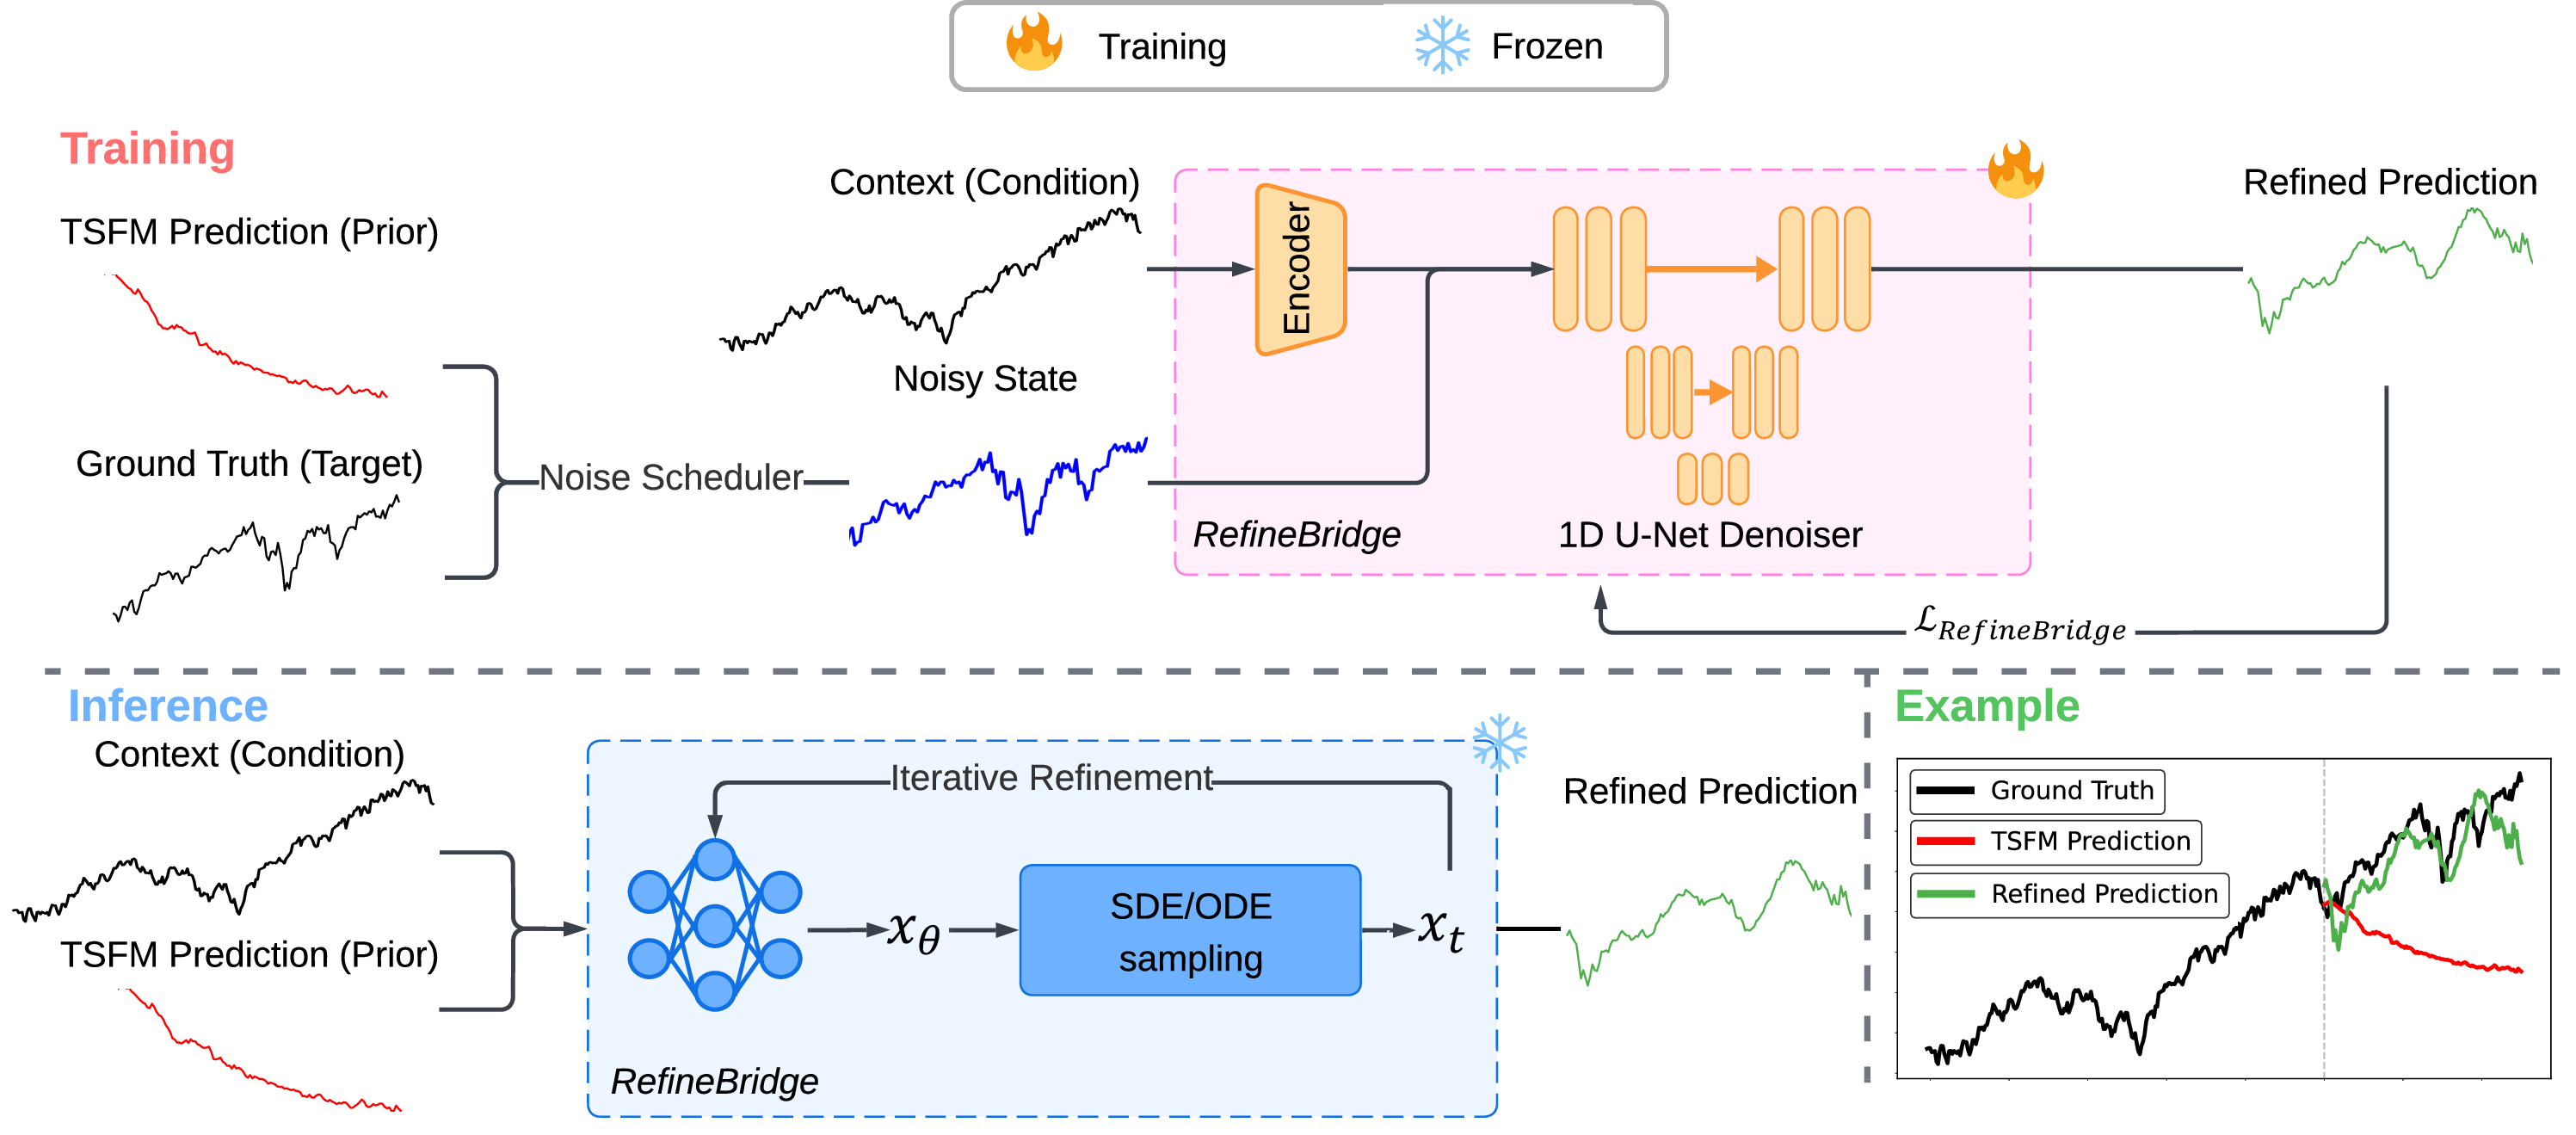
RefineBridge: Generative Bridge Models Improve Financial Forecasting by Foundation Models
[ICASSP 2026] International Conference on Acoustics, Speech and Signal Processing 2026 Oral (1 of 866 oral presentations among 4,589 accepted papers, selected from 11,200 submissions; 19% of accepted papers · 8% of submissions)
We address financial forecasting with a context-conditioned Schrödinger bridge that refines predictions from frozen time-series foundation models. The learned stochastic transport progressively improves initial forecasts using historical observations, with accuracy gains across multiple financial benchmarks and prediction horizons.
Paper Oral Slides Code soon
Academic service
Conference Reviewer: ICRA'27, ICASSP'27.